About me
I am currently a Ph.D. student in
The Department of Electrical & Computer Engineering at the University of Florida,
advised by Dr.
Ivan Ruchkin, who leads the Trustworthy Engineered Autonomy (TEA) Lab. I earned my master's degree in Electrical and Computer Engineering at the University of Florida in May 2025. Previously, I pursued graduate coursework in Electrical and Systems Engineering at the University of Pennsylvania. I received my bachelor's degree in Microelectronics Science and Engineering from the Southern University of Science and Technology (SUSTech), China, in 2022, where I was also a member of Pan Group@SUSTech
and studied high-speed communication interfaces with Dr. Quan Pan. I also interned at the
Brain-inspired Computing Lab
at the Guangzhou campus of the Hong Kong University of Science and Technology (HKUST-GZ), where I worked on spiking neural networks (SNNs) and event cameras under the supervision of
Dr. Renjing Xu.
Research Interests:
-
Safe Autonomous Systems and LLM Agents: Modeling, analysis, monitoring, and prediction; confidence measurement for reliable autonomous systems and LLM agents.
-
Uncertainty Quantification and Temporal Confidence Calibration: in large language models (LLMs), vision-language models (VLMs), and vision-language-action models (VLAs).
-
Physically Interpretable World Models: representation learning and world models that support physically meaningful prediction.
|
News
-
[2026]
Our paper "Reading the Prompt Back: Detecting Prompt-Consistency Hallucinations in Text-to-Video Generation" has been accepted to the 2027 IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), Orlando, FL, USA.
-
[Pinned]
I am always happy to discuss reliable AI agents, world models, and how to build useful AI systems. Please feel free to reach out.
-
[2026]
My thesis proposal "When Does an Agent Know It Is Lost? Confidence Trajectory Analysis for Tool-Using LLMs" has been accepted to the Student Research Workshop at the 64th Annual Meeting of the Association for Computational Linguistics (ACL), 2026.
-
[2026]
Our paper "Attack Resilience of UAVs with Embedded FPGAs" has been accepted to the IEEE Dallas Circuits and Systems Conference (DCAS), 2026.
-
[2026]
Our paper "Anomaly-Informed Confidence Calibration for Vision-Based Safety Prediction" by Zhenjiang Mao, Jiawen Wu, Gabriel Wagner and Ivan Ruchkin has been accepted to the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Pittsburgh, PA, USA.
-
[2026]
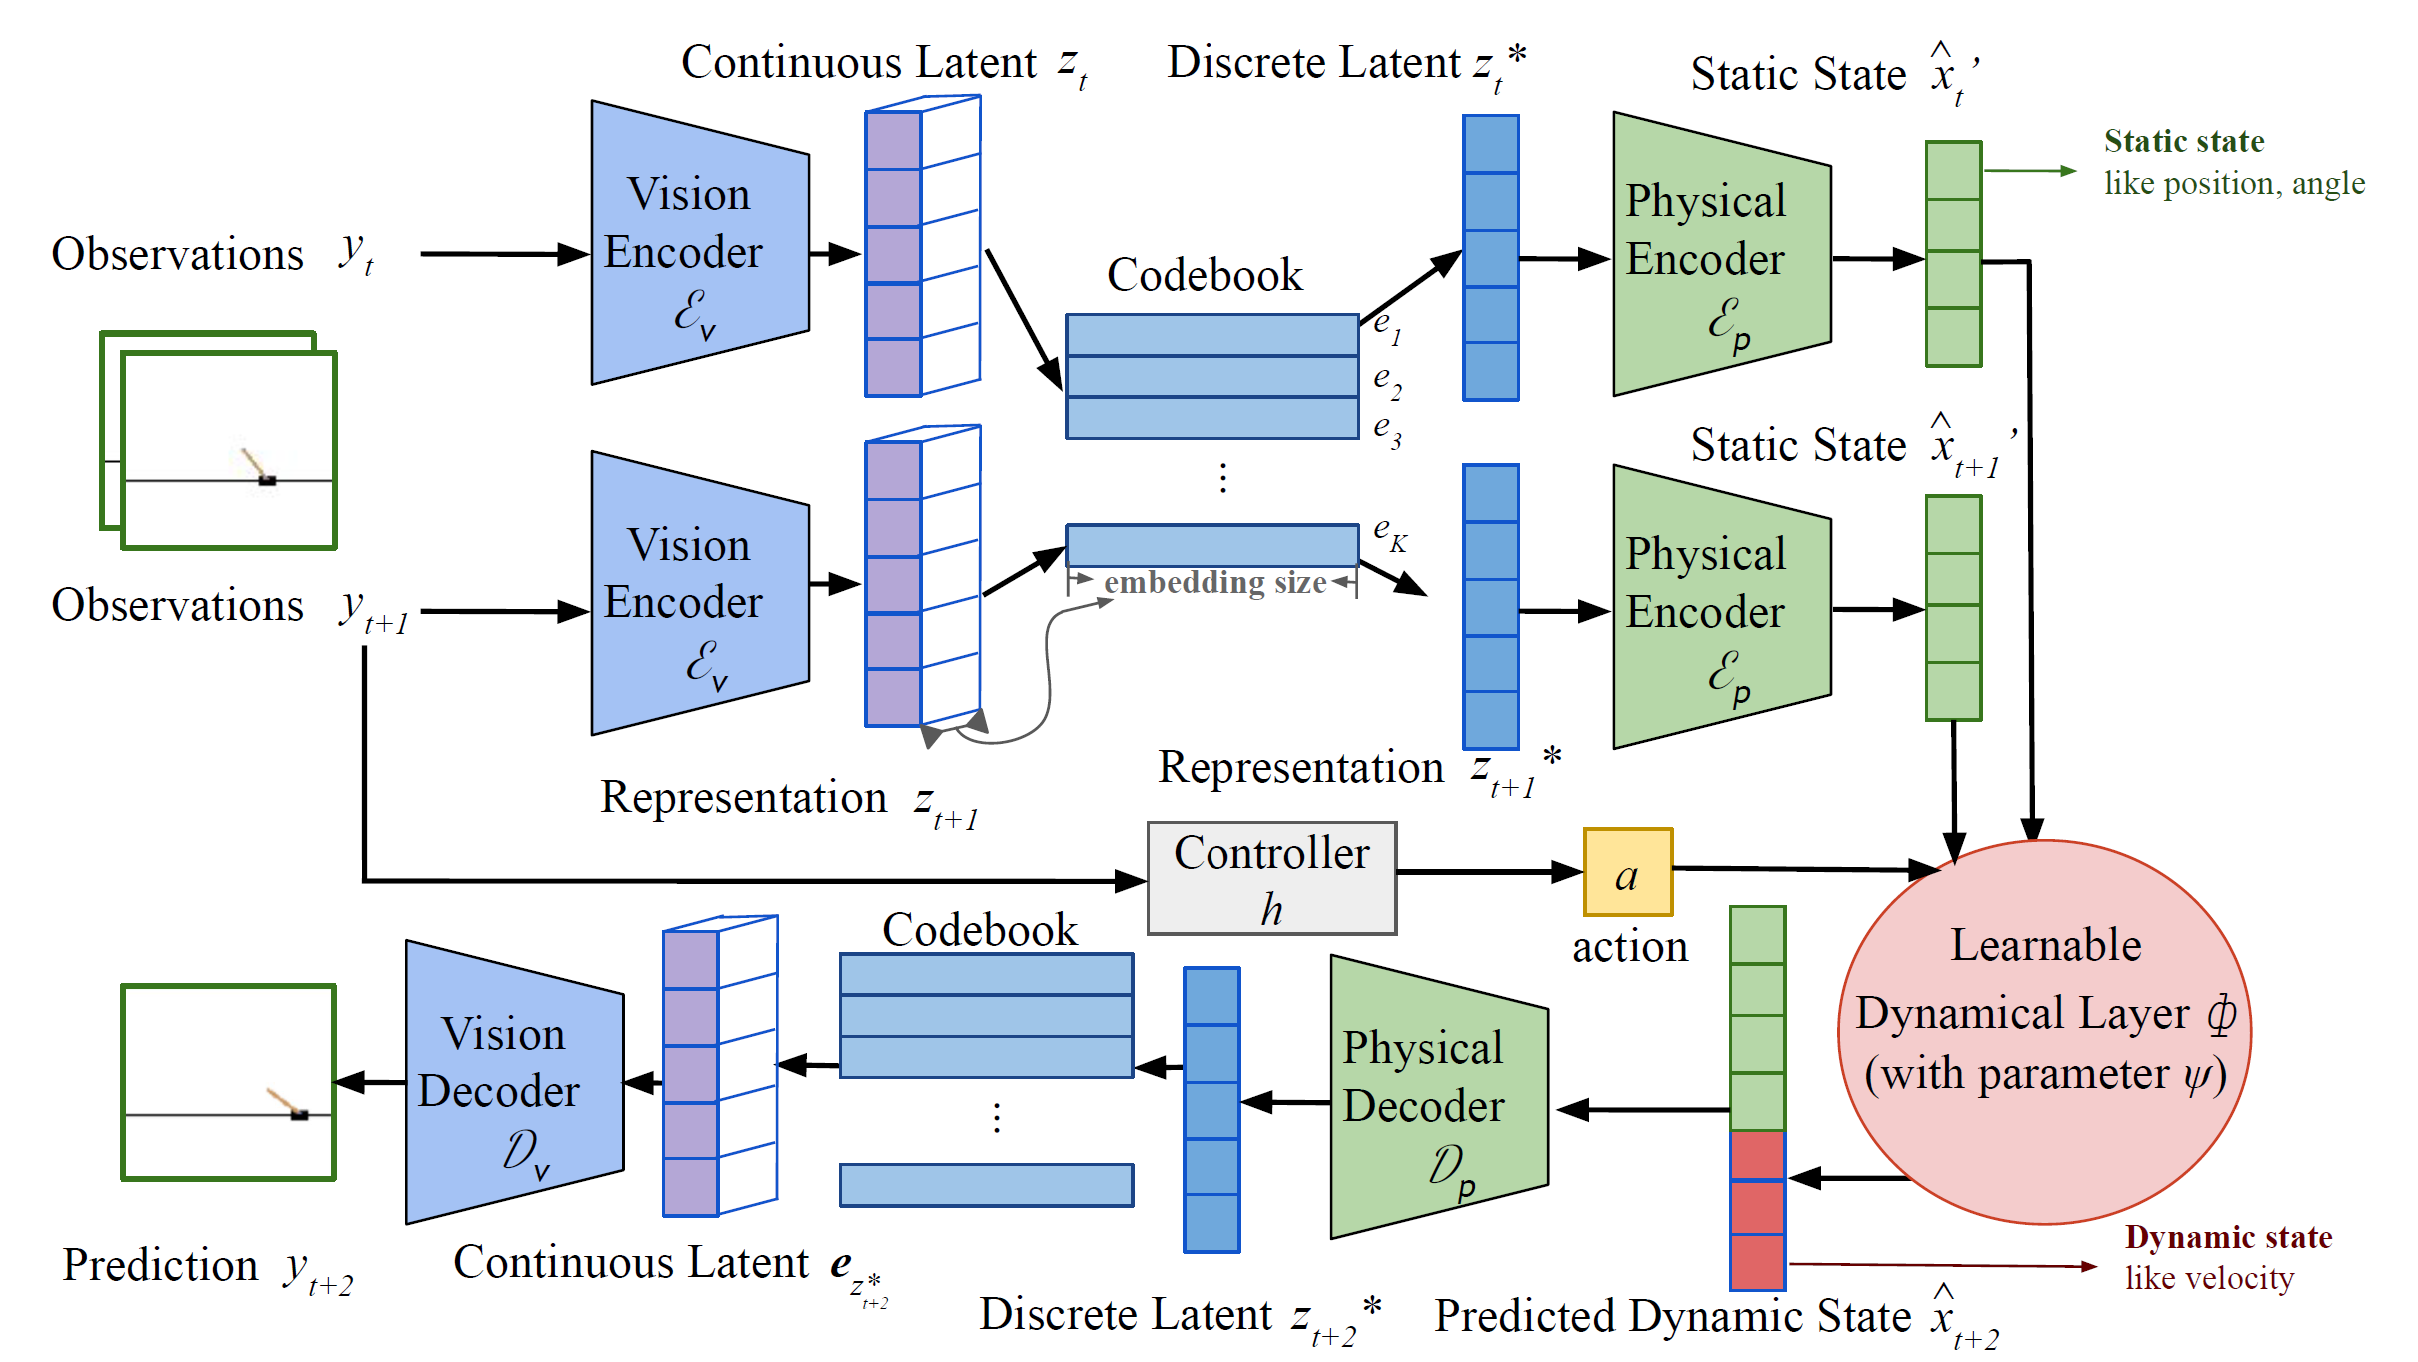
Our paper "Physically Interpretable World Models via Weakly Supervised Representation Learning" by Zhenjiang Mao, Mrinall Eashaan Umasudhan and Ivan Ruchkin has been accepted to HSCC & ICCPS '26: 29th ACM International Conference on Hybrid Systems: Computation and Control, and 17th ACM/IEEE International Conference on Cyber-Physical Systems (with CPS-IoT Week, Saint Malo, France, 2026).
-
[2026]
Our paper "Confidence over Time: Confidence Calibration with Temporal Logic for Large Language Model Reasoning" by Zhenjiang Mao, et al. has been accepted to the Findings of the Annual Meeting of the Association for Computational Linguistics (ACL), San Diego, CA, 2026.
-
[2026]
Our paper "Recurrent Confidence Chain: Temporal-Aware Uncertainty Quantification in Large Language Models" by Zhenjiang Mao, et al. has been accepted to ICASSP 2026 - 2026 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP), Barcelona, Spain, 2026.
-
[2025/05]
Our paper "Temporalizing Confidence: Signal Temporal Logic Evaluation of Multi-Step Chain-of-Thought Reasoning" by Zhenjiang Mao, Rohith Reddy Nama, Artem Bisliouk, and Ivan Ruchkin has been accepted to the 20th Workshop on Innovative Use of NLP for Building Educational Applications (BEA 2025) at the 63rd Annual Meeting of the Association for Computational Linguistics (ACL), Vienna, Austria, 2025.
-
[2025/05]
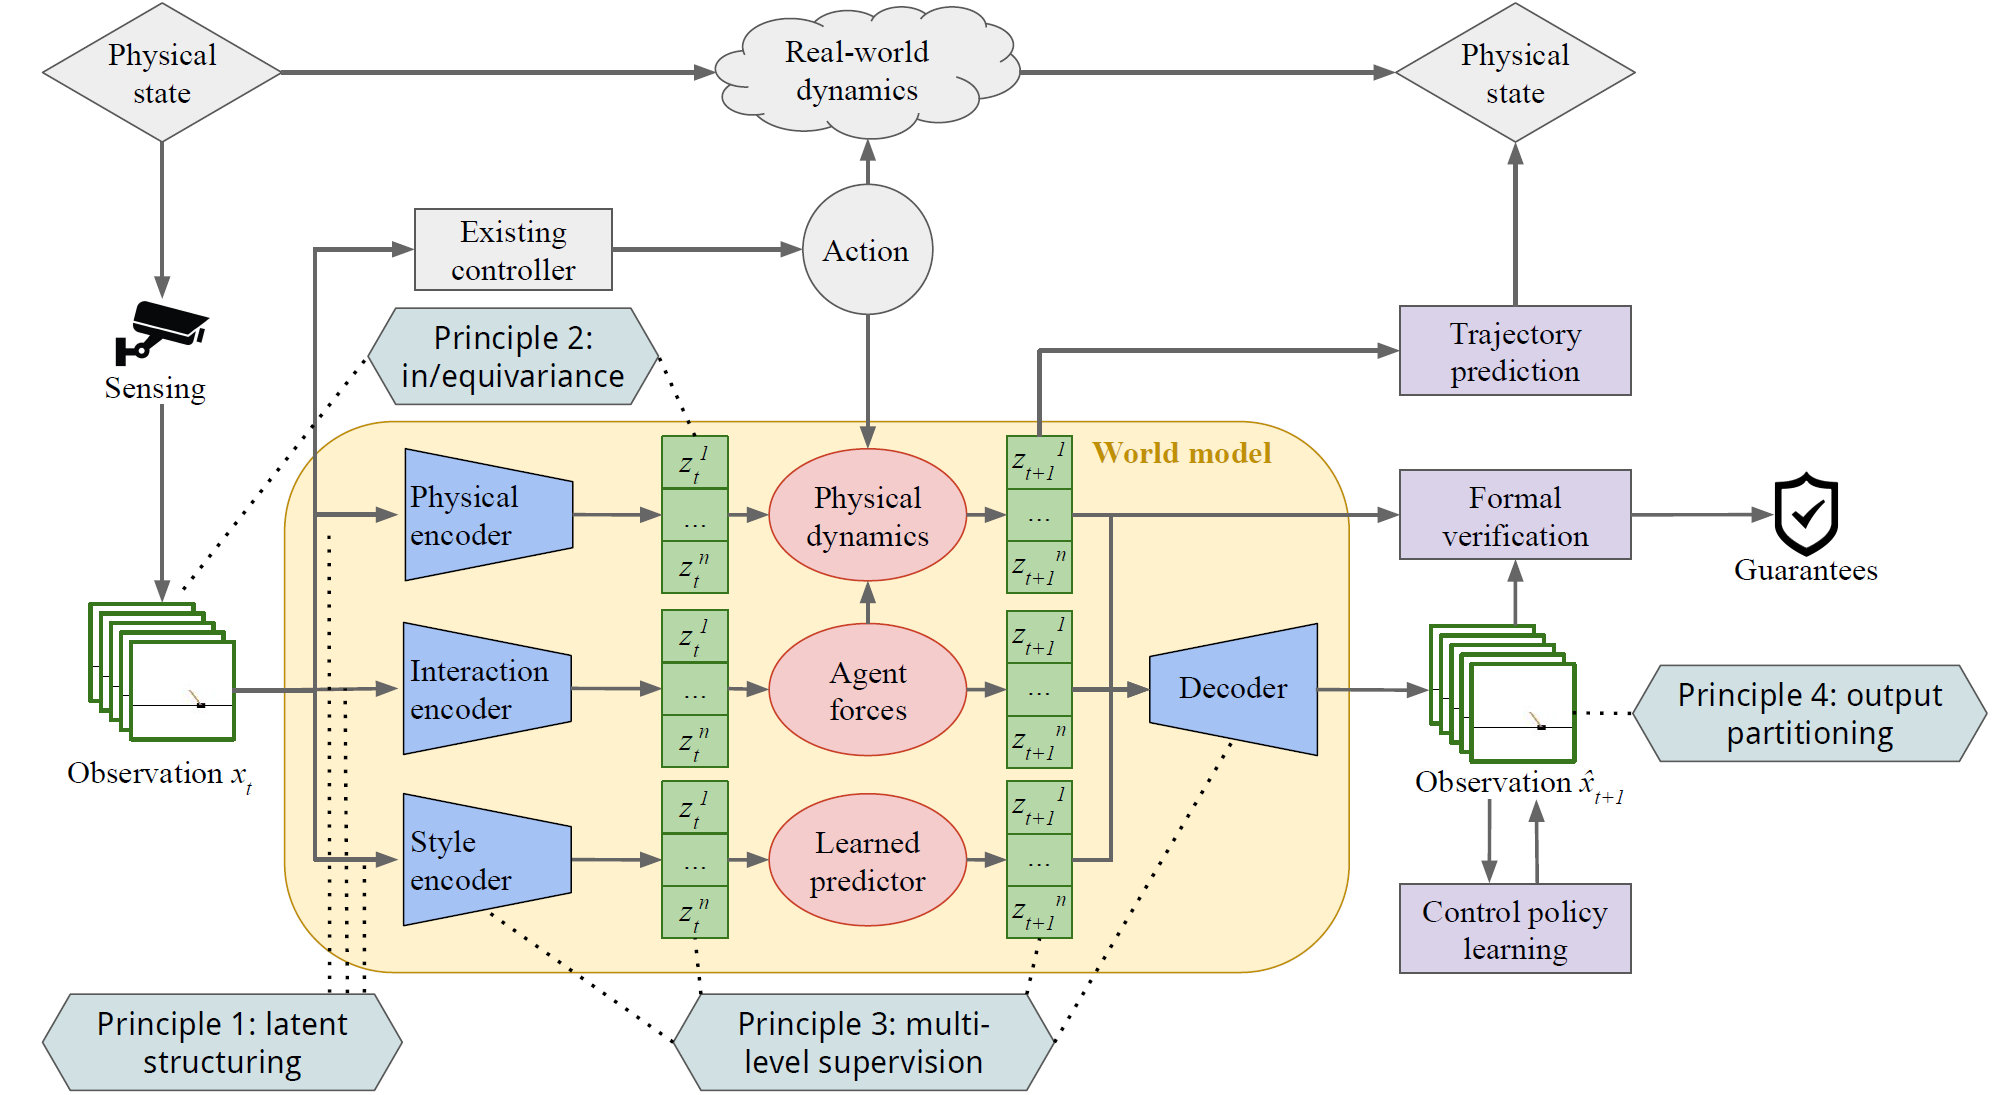
Our paper "Four Principles for Physically Interpretable World Models" has been accepted by International Conference on Neuro-symbolic Systems (NeuS), Philadelphia, PA, 2025.
-
[2025/04]
Our work "Four Principles for Physically Interpretable World Models" will be presented as a latest breakthrough at FMNS ICRA 2025 Workshop on Foundation Models and Neuro-Symbolic AI for Robotics in Atlanta.
-
[2025/03/15]
Three new preprints:
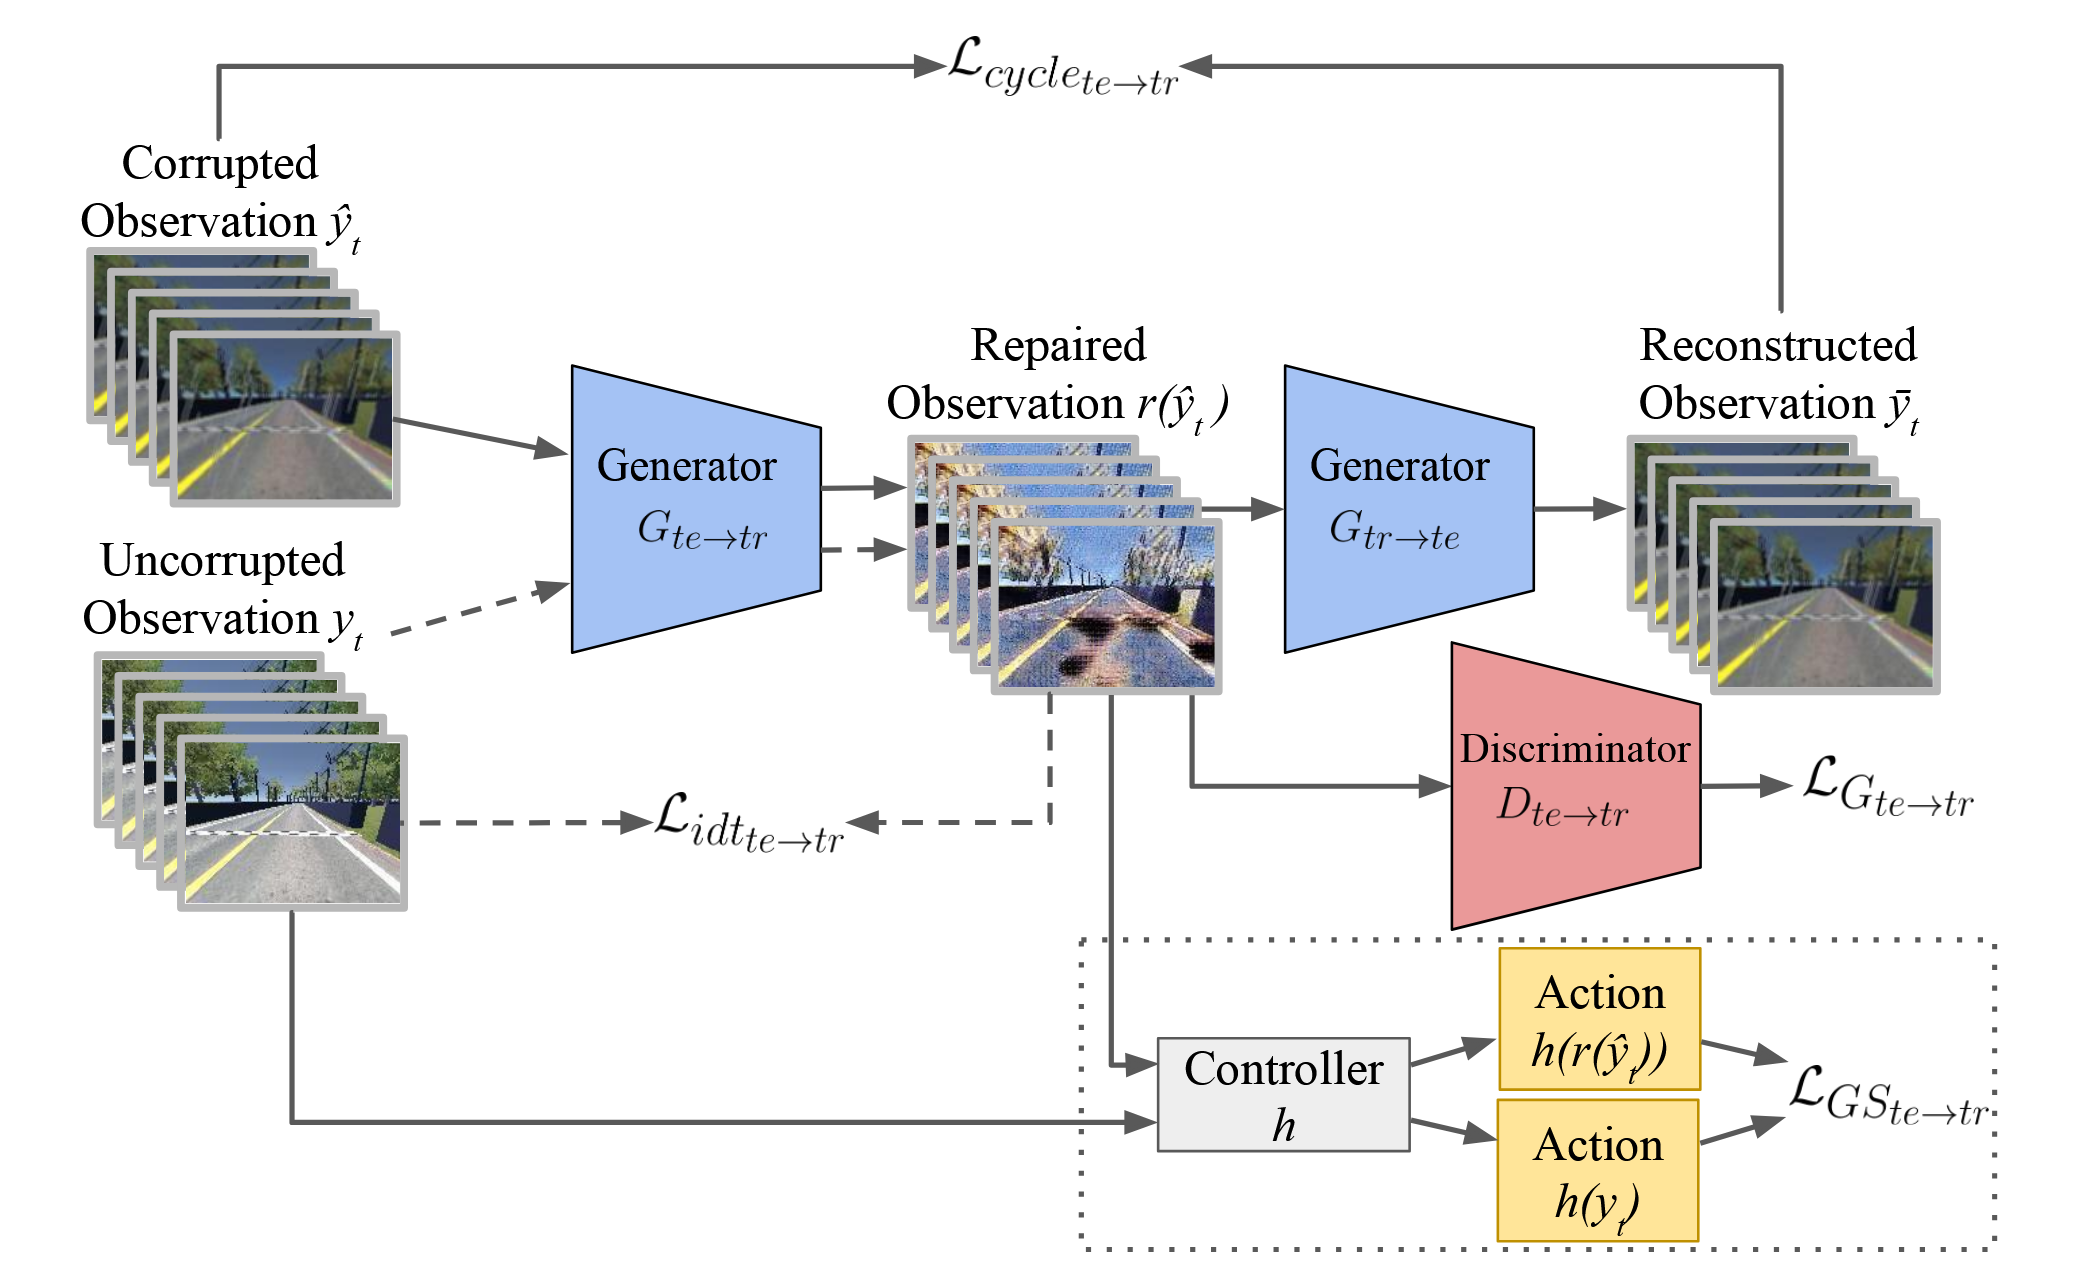
generalizable image repair
,
principles for interpretable world models
,
physically interpretable world models
-
[2025/02]
Invited talk at Brown Bag Seminar at UF: "Uncertainty in World Models for Learning Dynamics and Environments in Autonomous Systems"
-
[2024/10/04]
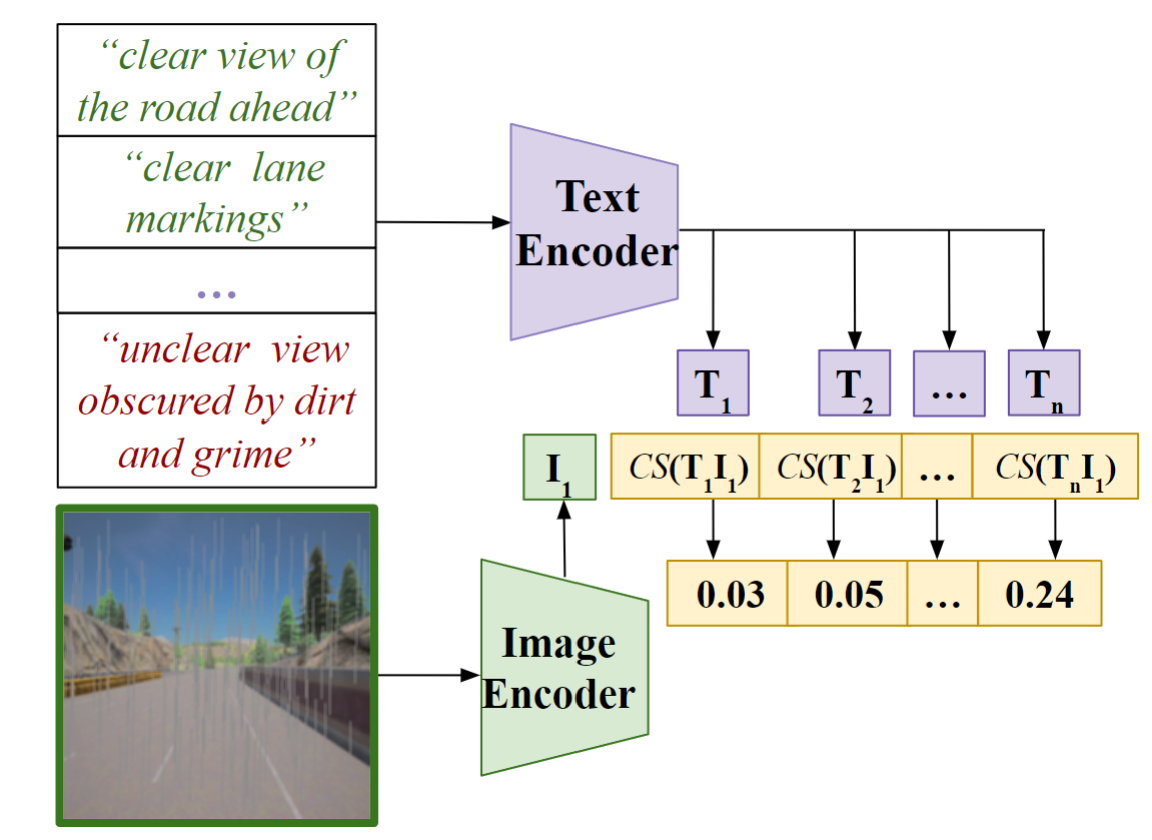
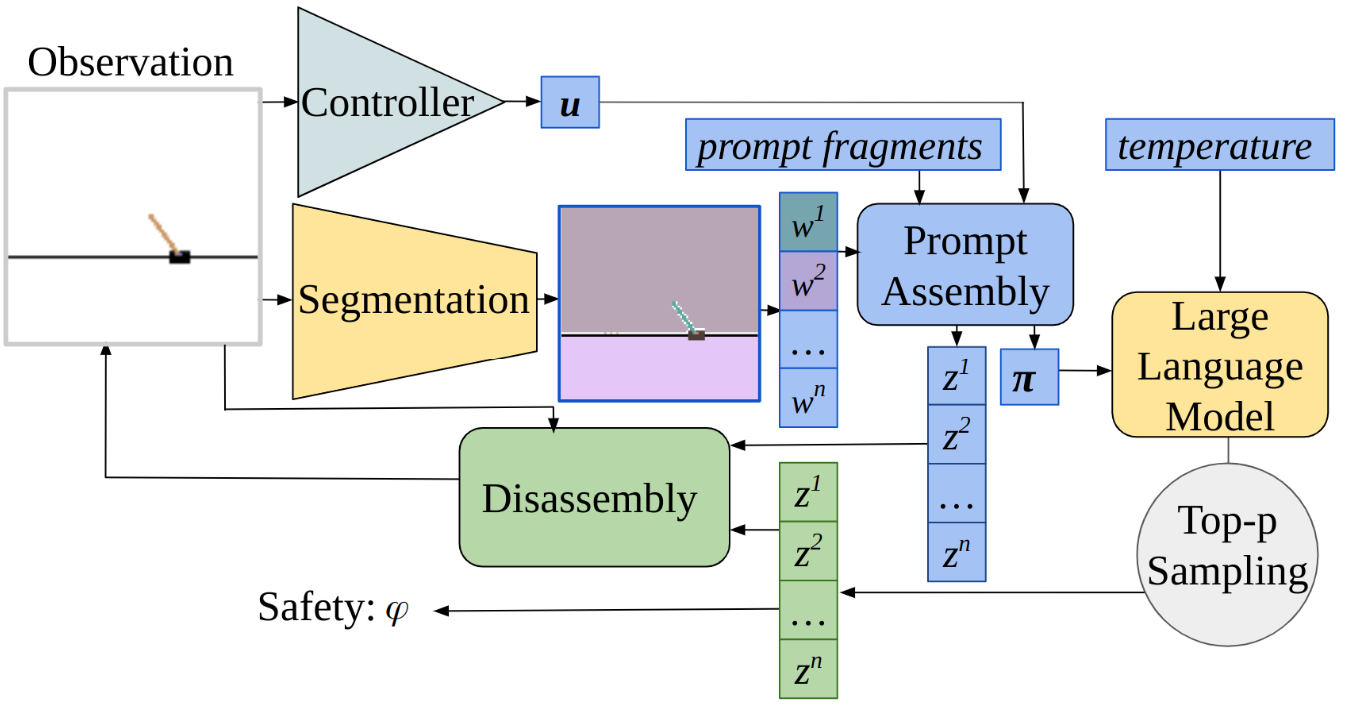
Invited talk at 2nd International Workshop on Trustworthy Autonomous Cyber-Physical Systems (Raleigh, NC): "How Safe Will I Be Given What I See? Calibrated Visual Safety Chance Prediction with (Foundation) World Models"
-
[2024/05]
Two workshop presentations at ICRA 2024:
- Robot Learning Going Probabilistic Workshop: "Zero-shot Safety Prediction for Autonomous Robots with Foundation World Models"
- Robot Trust for Symbiotic Societies (RTSS) Workshop: "Language-Enhanced Latent Representations for Out-of-Distribution Detection in Autonomous Driving"
-
[2024/03]
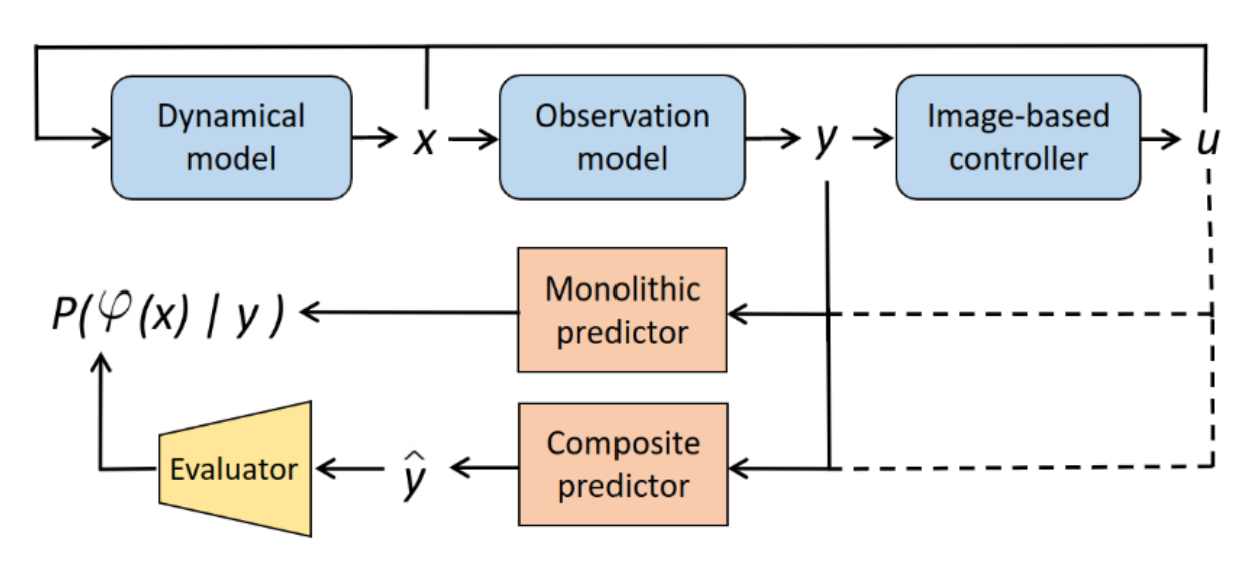
Invited talk at Brown Bag Seminar at UF: "How safe am I given what I see? calibrated prediction of safety chances for image-controlled autonomy"
-
[2024/04/09]
One paper workshop paper has been accepted by ICRA 2024 Workshop — Back to the Future: Robot Learning Going Probabilistic.
-
[2024/04/02]
One paper on
Calibrated Safety Prediction
has been accepted by 6th Annual Learning for Dynamics & Control Conference.
|